
 Kontakt
 Jak nakupovat

Doručení
Nákupní rádce
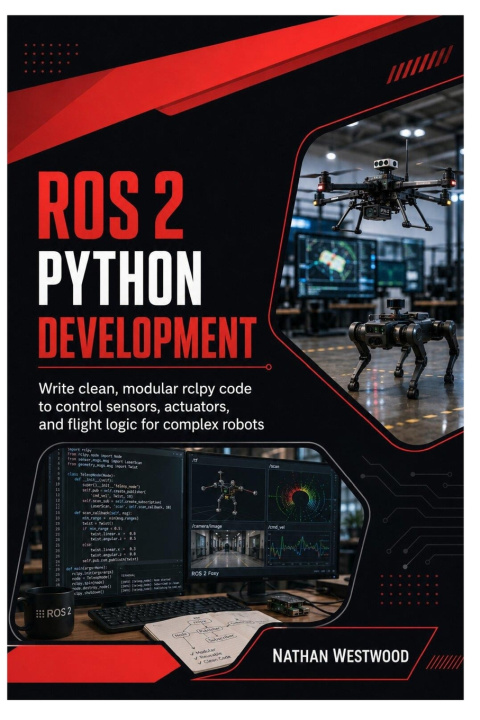
ROS 2 Python Development
Write Clean, Modular rclpy Code to Control Sensors, Actuators, and Flight Logic for Complex Robots
 Angličtina
 43 b
 Nové
Až 30 dní na vrácení zboží
Zákazníci také koupili


Build clean, modular ROS 2 robot software with Python and rclpy.
Modern robots are rarely controlled by one large program. A practical robot system is usually made of smaller components that read sensors, validate data, make decisions, check safety limits, command actuators, and report status.
ROS 2 Python Development shows you how to build that kind of robot software step by step using ROS 2, rclpy, workspaces, packages, nodes, topics, services, actions, parameters, launch files, sensors, actuators, transforms, and testable mission logic.
This practical beginner-friendly guide will help you:
- Understand ROS 2 nodes, topics, services, actions, parameters, messages, namespaces, and remapping
- Install ROS 2 Lyrical and prepare a clean development computer
- Create ROS 2 workspaces and ament_python packages
- Write your first rclpy node with logging, timers, callbacks, spinning, and clean shutdown
- Publish and receive data through ROS 2 topics
- Create clean custom messages, services, and action interfaces
- Use services for quick robot operations and actions for longer tasks with feedback and cancellation
- Organise robot settings with parameters, YAML files, and Python launch files
- Read and validate sensor data from range sensors, IMUs, position sources, and camera information
- Create sensor watchdogs, detect stale data, and publish processed sensor results
- Control motors, servos, and other actuators with validation, limits, timeouts, and emergency-stop behaviour
- Use ROS time, coordinate frames, tf2, transforms, robot state, and RViz
- Build mission and flight-state logic with idle, armed, takeoff, hold, land, and fault states
- Separate hardware drivers, safety checks, decision logic, and mission coordination
- Write clean, modular, responsive rclpy systems that avoid blocking callbacks and fragile global state
- Test Python logic, ROS nodes, publishers, subscribers, services, actions, timeouts, launch files, and complete system behaviour
- Use logs, rqt_graph, rqt_console, ros2 doctor, and ROS bags for repeatable debugging
The book builds one connected robot software stack rather than isolated demonstrations. You will create sensor input and validation nodes, actuator command and safety nodes, status and fault reporting, configurable limits, mission and flight-state logic, launch files, tests, and recorded data workflows.
The examples can run without a physical robot. Where hardware is discussed, the software is first tested with simulated or manually published data so that the architecture can be inspected before real movement is allowed.
Safety is treated as a core design requirement. Python nodes should coordinate high-level robot behaviour, not replace certified motor drives, actuator protection, or a flight controller's stabilisation loop. The book shows how to use command limits, stale-data checks, manual override, emergency-stop behaviour, fault handling, and staged hardware replacement.
Learn to build ROS 2 Python systems that are modular, inspectable, testable, and ready to grow from simulation toward real robot hardware.

Informace o knize
Angličtina

Darujte tuto knihu ještě dnes
Je to snadné
1 Přidejte knihu do košíku a zvolte doručit jako dárek 2 Obratem vám zašleme poukaz 3 Kniha dorazí na adresu obdarovanéhoMohlo by vás také zajímat


 /
 Pevná
 2 061
Kč
 /
Brožovaná
658
Kč

Ahoj! Jsem Libroamiko, tvůj knižní rádce.
Jak ti můžu pomoct?